

- Stock: In Stock
- Product code: 827588000002814243

More from this brand


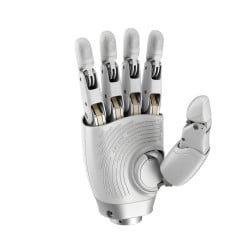
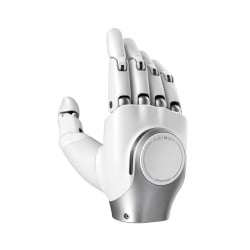
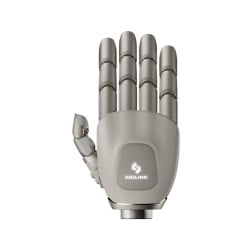
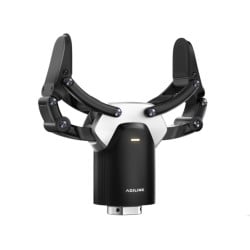
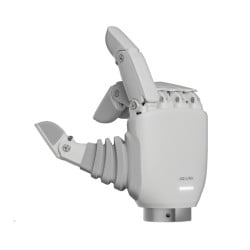
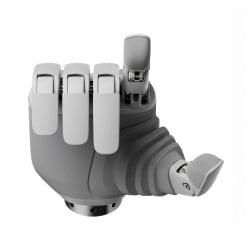
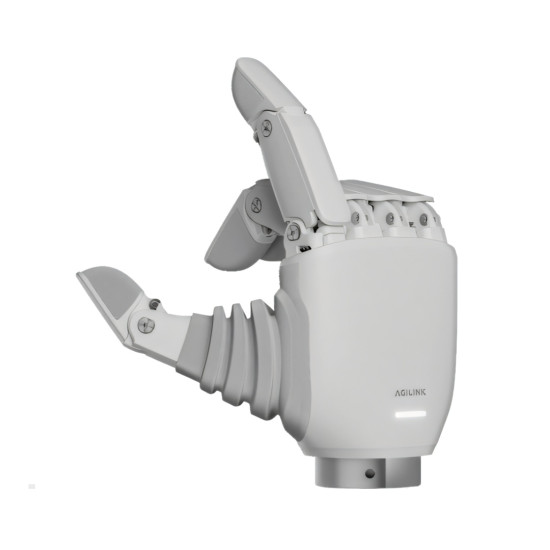
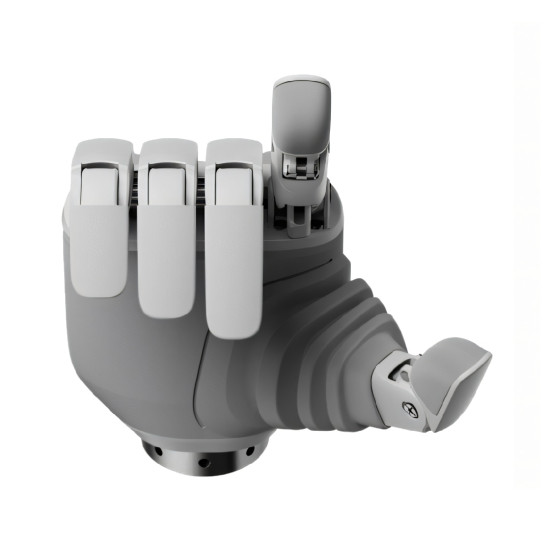
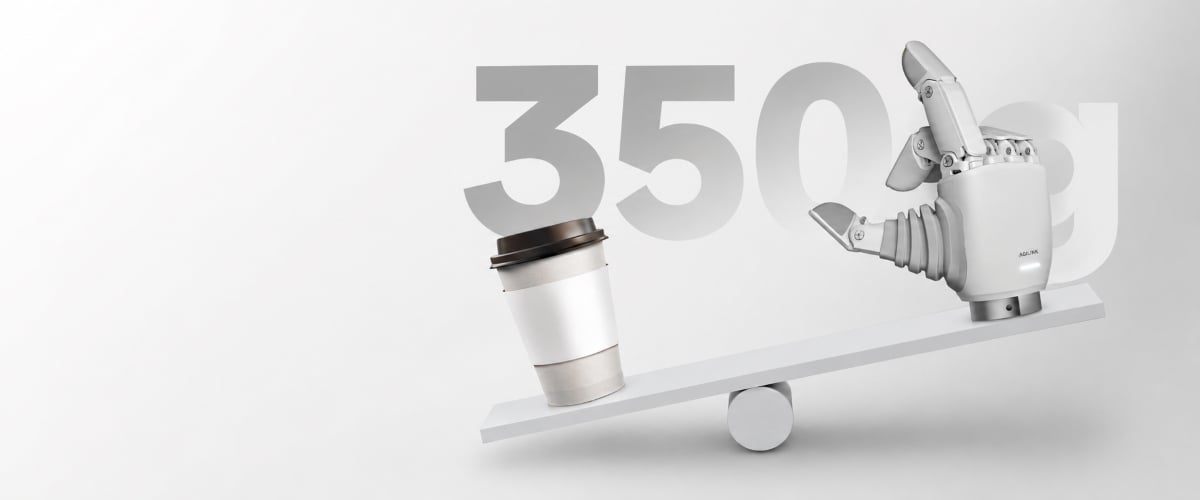
AgiBot OmniHand 3 Lite is a compact robotic hand designed for integration into humanoid platforms, mobile manipulators, and service robotic systems. The kinematic scheme has 4 active and 7 passive degrees of freedom, providing controlled finger movements and grip adaptation to the shape of the object. The hand is equipped with a tactile sensor and is designed to work with loads up to 1 kg. Weighing only 350 g and with compact dimensions, the OmniHand 3 Lite can be used with minimal load on the end of the manipulator.
Advantages of AgiBot OmniHand 3 Lite
- Compact and lightweight design. The weight of the OmniHand 3 Lite is only 350 g, making the hand lightweight for compact humanoid robots, mobile manipulators, and service platforms.
- Adaptive finger kinematics. The combination of 4 active and 7 passive degrees of freedom provides controlled movements and allows the fingers to adapt to the shape of the object upon contact.
- Working with objects weighing up to 1 kg. The allowable load is 1 kg, which determines the working range of object masses for gripping, holding, and moving.
- Durable construction with protective coating. The metal frame is complemented by a solid silicone coating that forms the contact surface and protects the hand elements during mechanical interaction.
- Compatibility with Dex-UMI. The hand can be used in remote control and motion capture systems for research tasks, robot training, and algorithm testing.
- Development tools. An open set of software tools allows for the creation of custom control algorithms, conducting experiments, and integrating the hand into research robotic systems.
Kinematics with Active and Passive Degrees of Freedom
OmniHand 3 Lite has 4 active and 7 passive degrees of freedom. Active degrees of freedom are controlled by drives and execute control system commands, while passive ones change position according to joint kinematics and mechanical interaction with the object.
The combination of active and passive movements provides controlled finger movement and grip adaptation to the shape of the object. The hand can use different finger positions when gripping and holding objects of various geometries.
Metal Frame and Silicone Coating
OmniHand 3 Lite is built on a sturdy metal frame, which forms a rigid base of the structure and withstands mechanical loads during hand movements.
The outer part has a solid silicone coating, creating a single contact surface and protecting internal components during interaction with objects. The design has passed tests for impacts, falls, and collisions, confirming the hand's suitability for use in robotic systems.
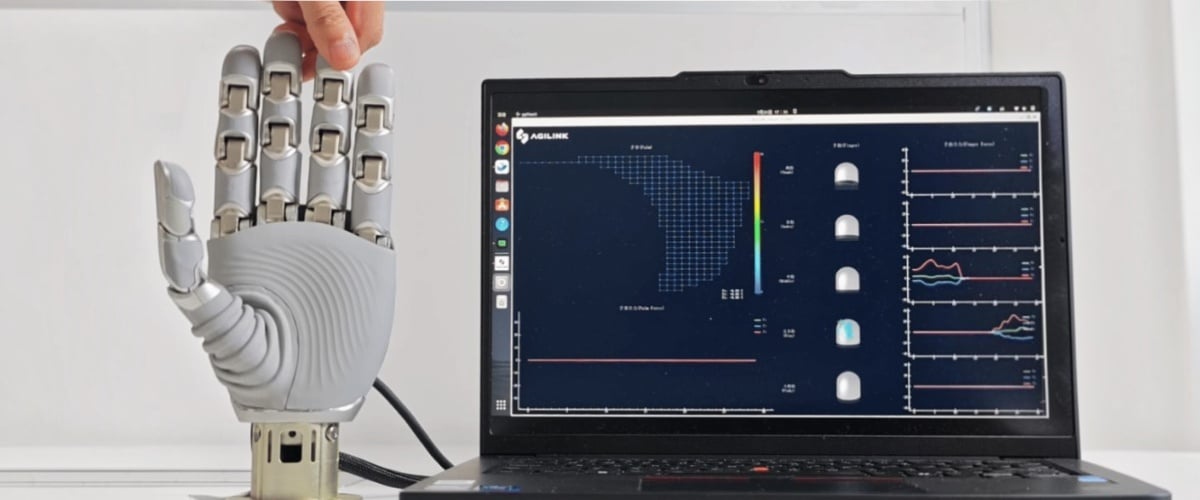
Tactile Sensor of OmniHand 3 Lite
OmniHand 3 Lite is equipped with a one-dimensional tactile sensor that registers physical contact of the hand with an object. The sensor resolution is 0.1. Tactile data complement information about finger positions and allow the control system to determine the moment of actual contact with the object. The obtained data can be used during gripping, holding, moving, and other contact operations. Sensor control helps to account for physical interaction between the hand and the object during repetitive manipulations and work with objects of different shapes.
Open Toolkit for Developers
OmniHand 3 Lite supports an open set of software tools for development and experimental work with robotic systems. The toolkit allows for creating and testing custom control algorithms, setting up laboratory stands, and integrating the hand into research projects.
Development capabilities are suitable for universities, research laboratories, system integrators, and teams engaged in prototyping and creating their own robotic solutions.
Fast Opening and Closing of the Hand
The typical time for full opening or closing of the OmniHand 3 Lite is 0.5 s. This parameter characterizes the speed of the main hand movement during gripping, releasing, and repetitive work with objects. The actual movement speed may depend on the load, operating mode, and settings of the specific robotic system.
Applications of AgiBot OmniHand 3 Lite
- Service robotics. Used as an end-effector module for working with objects and performing auxiliary manipulations.
- Mobile manipulators. Installed on mobile robotic platforms for gripping, holding, and moving objects.
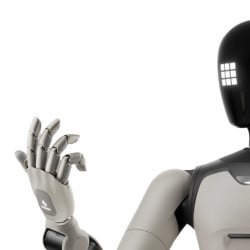
- Compact humanoid platforms. The low weight of the hand reduces the load on the manipulator and simplifies integration into compact robotic systems.
- Education and research. Used in universities, laboratories, and training centers to study kinematics, manipulator control, and contact interaction.
- Prototyping robotic systems. The open toolkit allows for creating and testing custom algorithms, experimental stands, and work scenarios.
Integration with Robotic Platforms
AgiBot OmniHand 3 Lite is designed for integration into compact humanoid platforms, mobile manipulators, and service robotic systems. When selecting a configuration, it is necessary to consider mechanical mounting, dimensions, allowable load, power parameters, and control system compatibility.
For data exchange, CAN FD and RS485 interfaces are provided. The ROS 2 software environment expands the possibilities of integrating the hand into robotic hardware and software complexes.
Technical Specifications of AgiBot OmniHand 3 Lite
| Parameter | Value |
| Degrees of freedom | 4 active + 7 passive |
| Load | 1 kg |
| Typical opening/closing time | 0.5 s |
| Positioning repeatability | ±0.5 mm |
| Tactile sensor | One-dimensional |
| Sensor resolution | 0.1 |
| Communication interfaces | CAN FD, RS485 |
| Control system compatibility | Dex-UMI |
| Software environment | ROS 2 |
| Development tools | Open set of tools |
| Frame material | Aircraft-grade metal frame |
| External coating | Solid silicone coating |
| Net dimensions | 140 × 70 × 32 mm |
| Net weight | 0.350 kg |
Order AgiBot OmniHand 3 Lite
AgiBot OmniHand 3 Lite is suitable for universities, research laboratories, robotics developers, system integrators, and enterprises needing a compact robotic hand for humanoid platforms, mobile manipulators, and service systems. Our specialists will help verify compatibility with the robotic platform, select a configuration, clarify connection and software control options, and check the availability of an additional wrist camera.