

- Stock: In Stock
- Product code: 827588000002811760

More from this brand


AgiBot X2 Ultra for Research, Navigation, and Robotics Projects
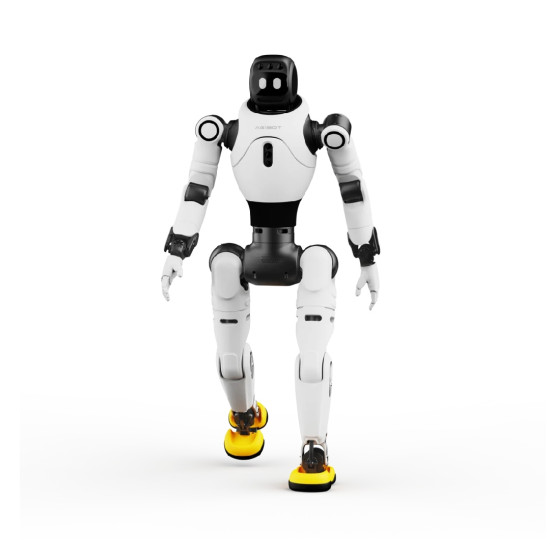
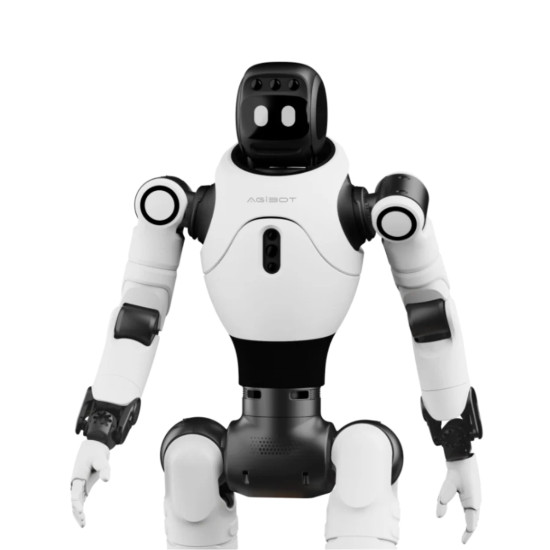
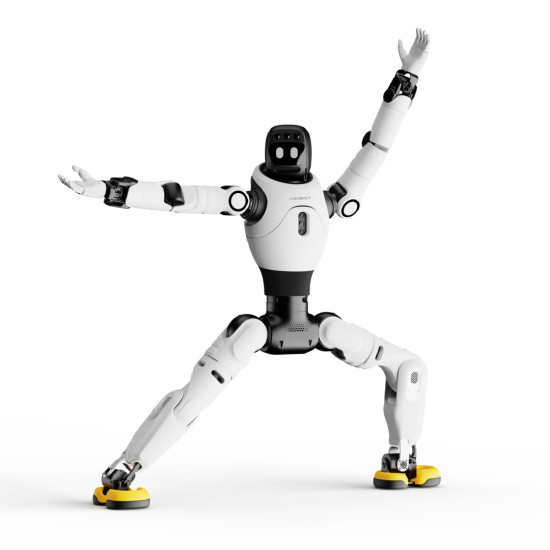
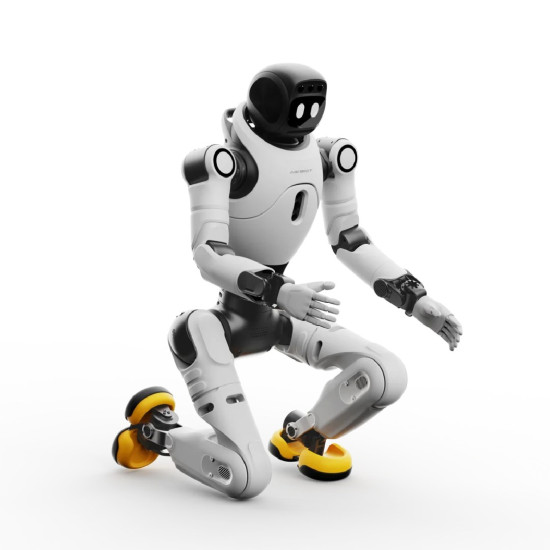
AgiBot X2 Ultra is a humanoid robot designed for interactive, navigational, research, and educational tasks. The kinematic system with 30 degrees of freedom ensures high mobility and a wide range of movements. For spatial orientation and environmental perception, the model is equipped with a sensor suite that includes 3D LiDAR, an RGB-D camera, two front RGB cameras, a rear RGB camera, and an interactive RGB camera. The computational system is based on two RK3588 modules and NVIDIA Jetson Orin NX with a performance of up to 157 TOPS. This configuration provides the necessary computational resources for processing sensor data, navigation, and artificial intelligence algorithms.
Advantages of AgiBot X2 Ultra
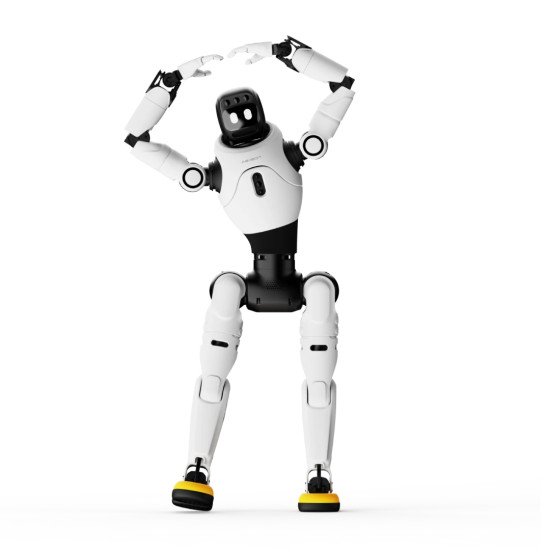
- 30 degrees of freedom. An advanced kinematic system ensures high mobility during walking, gestures, dance programs, and complex body movements. The design includes 7 degrees of freedom for each arm, 3 in the waist, 6 for each leg, and 1 in the neck module.
- Spatial perception. The combination of 3D LiDAR, RGB-D camera, and multiple RGB cameras allows the robot to gather data about the environment for navigation, spatial orientation, and research tasks.
- High computational performance. The NVIDIA Jetson Orin NX module with a performance of up to 157 TOPS combined with two RK3588 platforms provides resources for processing sensor data, navigation, and executing artificial intelligence algorithms.
- Support for secondary development. The X2 Ultra version allows creating custom software scripts and adapting the platform for research, educational, and specialized robotics projects.
- High movement speed. AgiBot X2 Ultra reaches speeds of up to 1.8 m/s, expanding the possibilities for use in navigational, demonstration, and interactive scenarios. The typical working speed is up to 0.8 m/s.
- Manipulators with 7 degrees of freedom. Movable arms provide a wide range of manipulations and support the installation of various end-effectors. The maximum reach of the arm is 558 mm, with a permissible load of up to 3 kg in specified positions and up to 1 kg within the full working range.
- Multimodal interaction. Voice, visual, and tactile channels provide more natural communication with the user. The robot is equipped with a touch sensor, microphone array, wireless microphone, speaker, interactive display, and light indication.
Design and Kinematics of AgiBot X2 Ultra
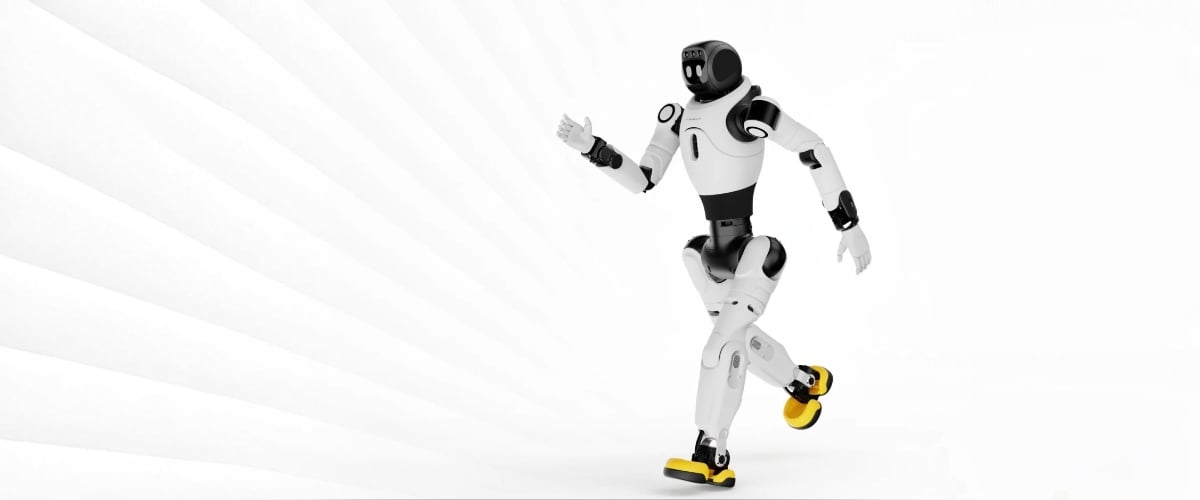
AgiBot X2 Ultra has a height of 1310 mm and a weight of approximately 39 kg. The robot's kinematic system includes 30 degrees of freedom. One degree of freedom is in the neck module, seven for each arm, three in the waist, and six for each leg. The maximum reach of the arm without an end-effector is 558 mm.
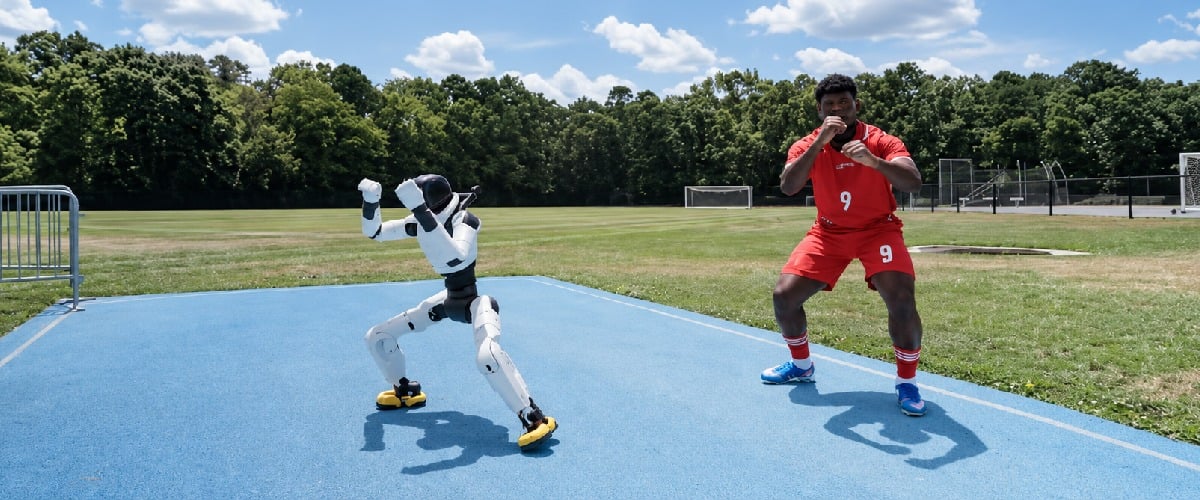
The movable waist provides turns, forward and side tilts, and coordinates the body position during walking. The arms and neck module allow for gestures, dance programs, and natural head movements synchronized with voice interaction. The peak torque in the joints reaches 120 N·m. The maximum walking speed is up to 1.8 m/s, and in laboratory conditions, it can reach 2 m/s. The typical working speed does not exceed 0.8 m/s.
Manipulators and Object Handling
The permissible load for AgiBot X2 Ultra is up to 3 kg in specified positions and no more than 1 kg within the entire working range. The robot's basic configuration does not include a fixed type of hand. Compatible OmniHand and OmniPicker modules are selected and ordered separately according to the specific project tasks. The number of fingers, presence of tactile sensors, grip parameters, and other characteristics are determined by the chosen end-effector.
The parameters of the manipulator and the installed hand need to be considered separately for each configuration. The manufacturer does not provide separate values for manipulator positioning accuracy and force control parameters for the basic configuration.
Sensors and Spatial Perception
AgiBot X2 Ultra is equipped with 3D LiDAR, an RGB-D camera, an interactive RGB camera, two front RGB cameras, a rear RGB camera, and a touch sensor on the head.
The interactive RGB camera is used for face, object, and gesture recognition, as well as for analyzing the semantics of the surrounding environment. The RGB-D camera generates depth data for three-dimensional space perception. The multi-line LiDAR creates a point cloud necessary for high-precision positioning and 3D SLAM algorithm operation.
Based on LiDAR and RGB-D data, the robot can perform autonomous route planning. LiDAR, the RGB-D camera, front stereo imaging, and the rear camera are used for obstacle detection. The manufacturer notes that autonomous movement and navigation functions require the installation of an advanced autonomous movement package. For voice interaction, a microphone array, wireless microphone, and speaker are provided. The sensor on the head responds to touch with a corresponding head movement.
Scenarios for AgiBot X2 Ultra
- Humanoid robotics research. Working with kinematics, walking, sensor data, and control algorithms.
- Laboratory projects. Practical work with 30 degrees of freedom, LiDAR, RGB-D, RGB cameras, and Orin NX.
- Navigation tasks. Route planning and obstacle avoidance are available in the corresponding configuration with the autonomous movement package.
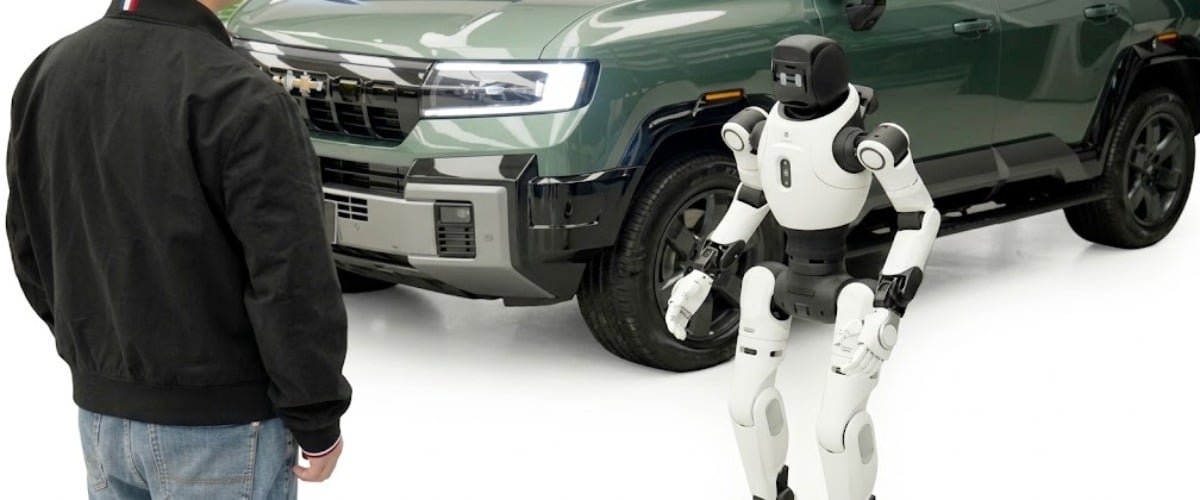
- Exhibitions and presentations. The model can function as an interactive guide or representative in public spaces.
- Interaction with people. Cameras, microphones, speaker, touch sensor, screen, and light effects form multiple channels of contact with the user.
- Object manipulation. Arms with 7 degrees of freedom are compatible with OmniHand and OmniPicker, which are ordered separately.
- Automatic charging. This mode requires a suitable charging station and an autonomous movement package.
Package Contents of AgiBot X2 Ultra
The standard package of AgiBot X2 Ultra includes the robot, charger, remote control, microphone, and documentation.
- Humanoid Robot AgiBot X2 Ultra. Main robotic module.
- Charger. Designed for charging the equipment.
- Remote control. Designed for manual control.
- Microphone. Designed for voice interaction.
- Quick user guide. Contains basic information for the first launch.
- Certificate of conformity. Document from the standard supply package.
Note: the exact supply composition and list of available options should be clarified before ordering.
Technical Specifications of AgiBot X2 Ultra
Design and Movement
| Characteristic | Value |
| Net dimensions | 1310 × 460 × 210 mm |
| Net weight | 39 kg |
| Total number of degrees of freedom | 30 |
| Degrees of freedom of the neck | 1 |
| Degrees of freedom of one arm | 7 |
| Degrees of freedom of the waist | 3 |
| Degrees of freedom of one leg | 6 |
| Arm reach | 558 mm |
| Operating temperature | -10℃ - 40℃ |
| Peak joint torque | 120·N·m |
| Walking speed | up to 1.8 m/s, ≤ 0.8 m/s |
| Permissible load | up to 3 kg |
Manipulators, Sensors, and Computing
| Characteristic | Value |
| RGB cameras | Interactive RGB camera, dual front RGB camera, rear RGB camera |
| Audio system | Microphone array, wireless microphone, speaker |
| Display | Interactive screen, light effects |
| Main computing boards | RK3588 ×2 |
| High-performance computing module | Orin NX |
| Computational performance | 157 TOPS |
| Secondary development | Supported |
| Network updates | Supported |
| Mobile application | Supported |
Power, Communication, and Interfaces
| Characteristic | Value |
| Battery capacity | 500 Wh |
| Working time | 2 hours |
| Power supply method | Direct charging, removable battery, optional automatic charging station |
| Charging time | ≤ 1.5 hours |
| Input voltage | 100–220 V |
| Charger output | 54.6 V, 10 A |
| Wireless communication | Wi-Fi, Bluetooth, 4G/5G module |
| USB | Type-A ×2, Type-C ×2 |
| Network ports | RJ45 ×2 |
| Video output | Mini DisplayPort |
| Power outputs | 12 V / 3 A, 48 V / 5 A |
| Handheld controller | Included |
Buy the AgiBot X2 Ultra Humanoid Robot
AgiBot X2 Ultra is suitable for research and educational projects, laboratory work, navigation scenarios, interactive solutions, and presentations. Our specialists will help you choose the configuration, end-effectors, and additional packages according to the tasks of your project.

































