

- Stock: In Stock
- Product code: 827588000002811842
- SKU: AgiBot-X2-REC

More from this brand


AgiBot X2 REC for Robotic Data and Research Projects
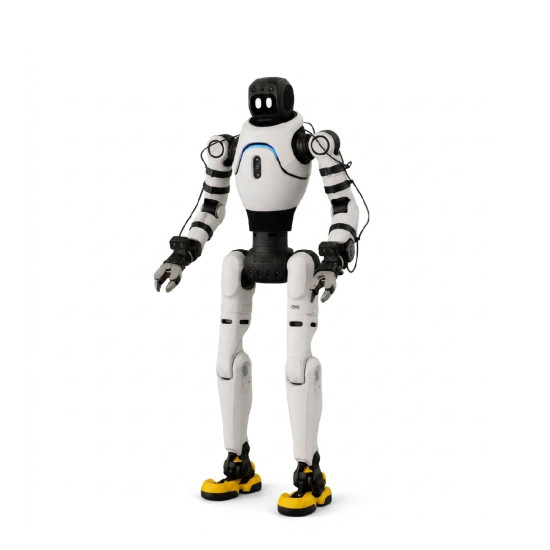
AgiBot X2 REC is a humanoid robot from the X2 series for data recording in real-world conditions, operations, and research of robotic models. The model has a height of 131 cm, a weight of 40 kg, and 30 degrees of freedom, with 7 allocated to each arm. The sensor equipment includes RGB, RGB-D, stereo cameras, LiDAR, and IMU, and computational tasks are performed by NVIDIA Orin NX with 16 GB of memory. Remote control options include VR, a controller, and motion tracking. Genie Studio forms a workflow of recording demonstrations, training, testing, and deploying custom VLA models.
Main Advantages of AgiBot X2 REC
- Data collection in real-world conditions. X2 REC is designed for recording robotic demonstrations and forming datasets for research and applied tasks. The manufacturer positions this configuration as a humanoid platform for data collection directly in a real environment.
- Teleoperation and full-body motion control. The operator can control the robot's movements during demonstration recording, scenario execution, and algorithm testing. Remote control support includes VR, controllers, and motion tracking systems.
- 30 degrees of freedom. The advanced kinematic system allows for reproducing and recording complex full-body movements, including intricate action sequences. X2 REC is claimed to have 30 degrees of freedom.
- Manipulators with 7 degrees of freedom. Each arm has 7 degrees of freedom, expanding possibilities for exploring manipulations, movement trajectories, and object interactions. The declared payload of one arm is up to 3 kg.
- Multichannel machine vision system. Cameras located in different parts of the body provide data from multiple viewpoints for computer vision tasks, teleoperation, and robotic manipulations. The configuration includes RGB and RGB-D cameras, stereo vision, as well as visual modules in the head, chest, back, and wrists.
- LiDAR and IMU. LiDAR and the inertial measurement unit provide spatial and inertial data that can be used for the development and testing of orientation, localization, and motion analysis algorithms. The actual level of autonomy depends on the implemented software and specific work scenario.
- Support for various end effectors. The robot's configuration can be adapted for specific manipulation tasks and demonstration collection. X2 REC is noted to support, among others, OmniHand and OmniPicker 3.
- Full data workflow in Genie Studio. Recorded demonstrations can be used for further preparation and development of robotic models. For X2 REC, a cycle is provided that encompasses data collection, training, testing, and deployment of custom VLA models.
Design and Kinematics of AgiBot X2 REC
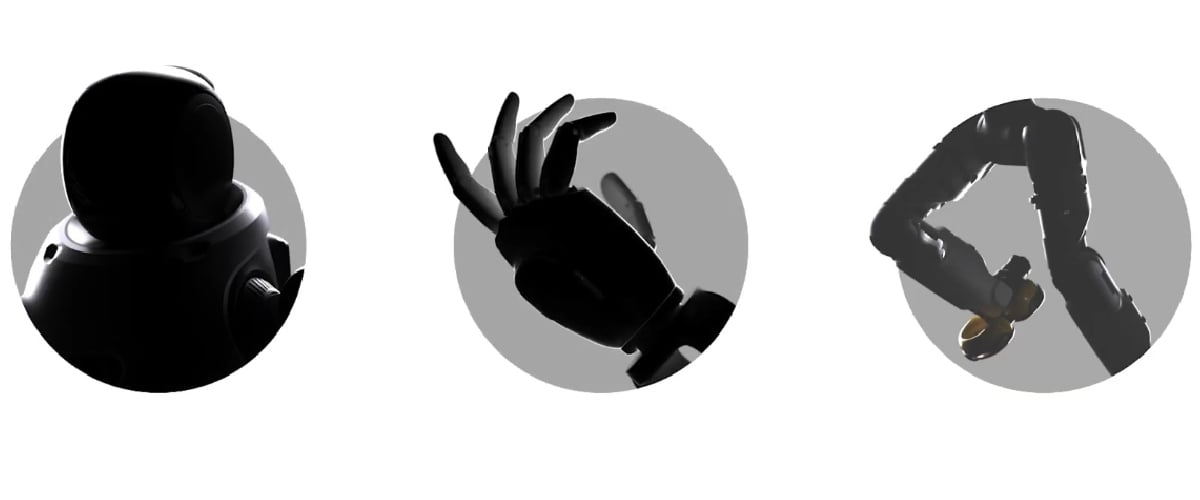
The humanoid robotic platform AgiBot X2 REC with a height of 131 cm and a weight of 40 kg is designed for data collection, teleoperation, and full-body motion control research. The robot's kinematic system has 30 degrees of freedom, with 7 degrees of freedom allocated to each arm. This configuration allows for reproducing complex full-body movements, controlling the position of manipulators, and recording action sequences during remote control. For the REC version, the manufacturer separately notes the support of synchronized full-body teleoperation, which is important for recording demonstrations and forming training datasets.
Manipulators and Object Interaction
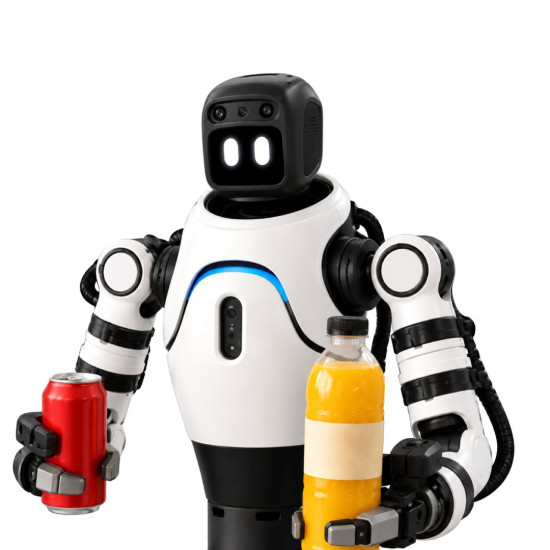
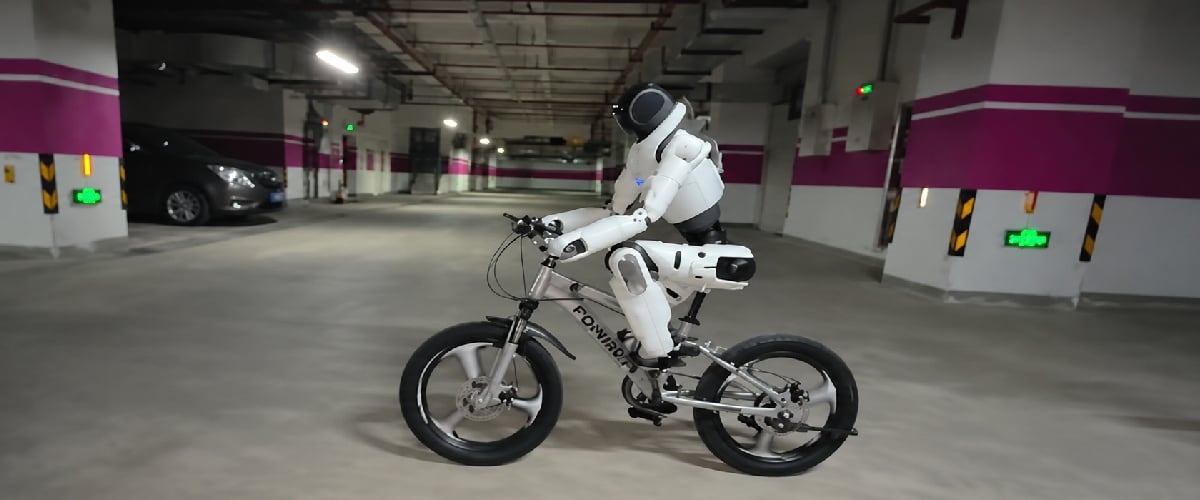
Each X2 REC manipulator has 7 degrees of freedom, providing a wide range of movements when working with objects and reproducing complex trajectories. The declared payload is up to 3 kg per arm. End effectors for this configuration include OmniHand and OmniPicker 3. The choice of a specific gripper depends on the nature of the experiment, the type of objects, and the data that needs to be obtained.
The platform can be used for recording scenarios of object grasping, moving, and placing, exploring manipulator kinematics, and creating datasets for training robotic models. The number of fingers, the presence of tactile feedback, and force control capabilities depend on the installed end effector and are not the same for all configurations.
Sensor System and Environmental Perception
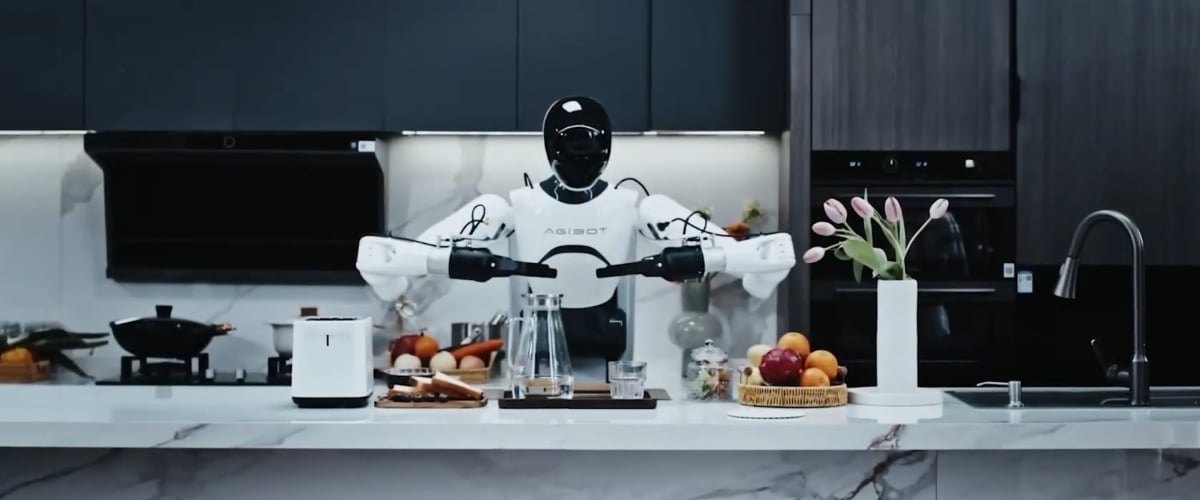
The REC version is equipped with a complex of sensors for collecting visual, spatial, and inertial data during movement and manipulations. The perception system includes RGB cameras, RGB D sensors, stereo cameras, LiDAR, and IMU.
Visual modules are located in several areas of the robot, including the head, chest, back, and wrists. This multi-view configuration allows for simultaneously capturing the work environment and the process of interacting with objects from different viewpoints.
LiDAR is used to obtain spatial data about the surrounding environment, and IMU records motion and orientation parameters of the body. Specific localization, navigation, object recognition, and autonomous behavior functions are determined by the software used and the settings of a specific scenario.
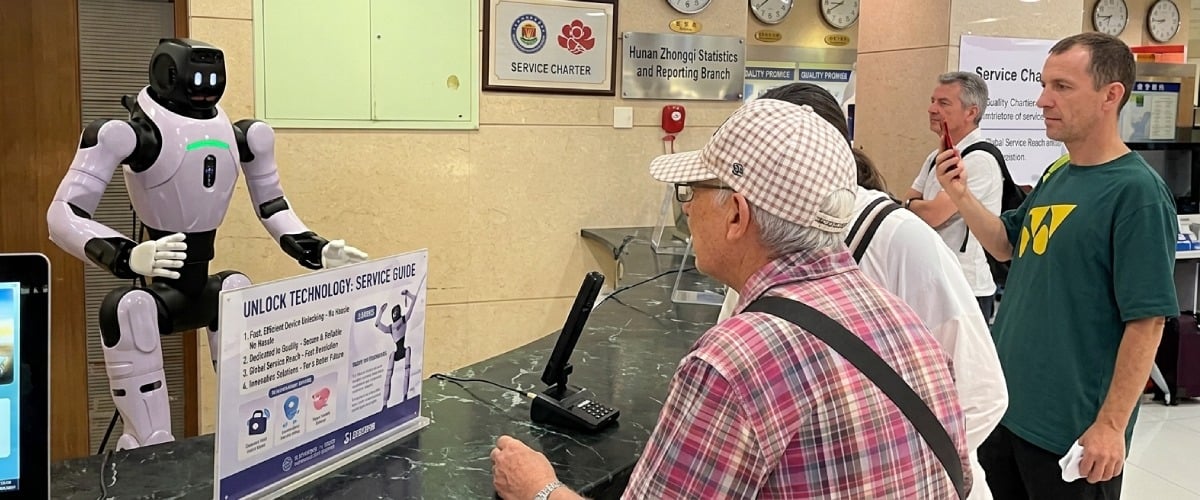
Computational Platform and Software Development
AgiBot X2 REC is equipped with a computational module NVIDIA Orin NX with 16 GB of memory, which is used for processing sensor data and executing robotic algorithms. The REC configuration is focused on full-body teleoperation and integration with Genie Studio. Motion control can be performed using VR systems, controllers, or operator motion tracking technologies. Data obtained during demonstrations can be used for training, testing, and verifying robotic models.
The open specification of X2 REC does not provide an exhaustive list of supported SDKs, APIs, programming languages, and hardware interfaces. Therefore, support for Python, C++, DDS, GStreamer, USB, Ethernet, and other technologies should be verified according to the documentation of the specific X2 REC configuration, without automatically transferring the characteristics of X2 Ultra, EDU, or other modifications.
Data Collection and Training of Robotic Models
One of the key purposes of AgiBot X2 REC is data collection in real-world conditions. The platform combines full-body teleoperation, a multichannel perception system, and Genie Studio tools for recording demonstrations and further working with the obtained datasets.
During remote control, body and manipulator movement trajectories, object operations, as well as synchronized camera, LiDAR, and IMU data can be recorded. This allows for forming comprehensive training samples that reflect the interaction of the physical robot with the real environment.
The workflow in Genie Studio covers sequential stages of data collection, training, testing, and model deployment. X2 REC is also positioned as a platform for developing and verifying custom VLA models that combine visual perception, language instructions, and physical action execution. This approach allows for initially recording necessary scenarios involving an operator and then using the obtained demonstrations as a basis for training and subsequent autonomous execution of corresponding tasks by the robotic system.
Applications of AgiBot X2 REC
X2 REC is designed for projects requiring physical demonstrations, remote control, and sensor stream recording for further work with robotic models.
- Robotic data collection. Recording movements, manipulations, and sensor information on a physical humanoid.
- Full-body teleoperation. Controlling the body and limbs via VR, controller, or motion tracking.
- Working with VLA models. Preparing data for training, testing, and deploying Vision-Language-Action models.
- Manipulation research. Recording the work of hands and end effectors during object interaction.
- Computer vision. Working with RGB, RGB-D, and stereo data from multiple body zones.
- R&D in humanoid robotics. Testing motion, perception, and behavior algorithms on physical equipment.
- Laboratory projects. Forming custom datasets and verifying robotic scenarios.
Technical Specifications of AgiBot X2 REC
Design and Movement
| Parameter | Value |
| Net Dimensions | 1310 × 460 × 210 mm |
| Net Weight | 40 kg |
| Total Degrees of Freedom | 30 |
| Degrees of Freedom per Arm | 7 |
| Payload | 3 kg |
| Motion Control | Full-body motion control |
Manipulators, Sensors, and Computation
| Parameter | Value |
| End Effectors | OmniHand, OmniPicker 3 |
| Visual Perception | RGB, RGB-D, stereo vision |
| Location of Visual Modules | Head, chest, back, wrists |
| LiDAR | Declared |
| Inertial Measurement Unit | IMU |
| Computational Module | NVIDIA Orin NX |
| Memory of Computational Module | 16 GB |
| Working with Models | Custom VLA models |
| Software Ecosystem | Genie Studio |
| Model Workflow | Data acquisition, training, testing, deployment |
Teleoperation and Data Handling
| Parameter | Value |
| Remote Control | VR, controller, motion tracking |
| Control Mode | Full-body movements |
| Data Handling | Genie Studio |
| Working with Models | VLA models |
Buy AgiBot X2 REC Humanoid Robot
AgiBot X2 REC is intended for data collection in real-world conditions, full-body teleoperation, working with VLA models, and research R&D projects. Our specialists will help select the configuration for specific tasks, clarify end effectors, computational module, configuration, current price, and delivery terms, and place an order.





































