

- Stock: In Stock
- Product code: 827588000004140413
- Weight Brutto: 28.00kg

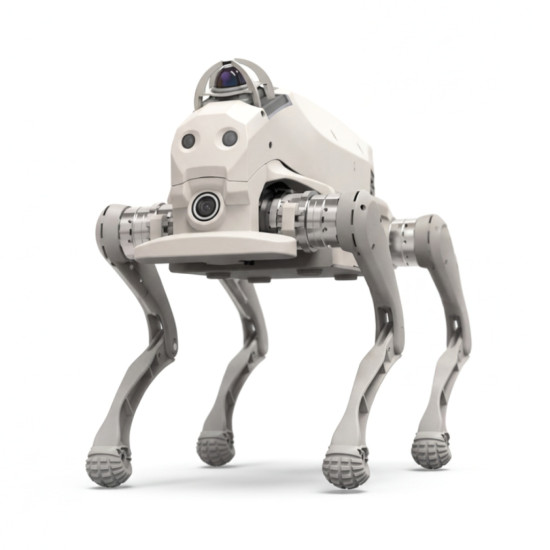
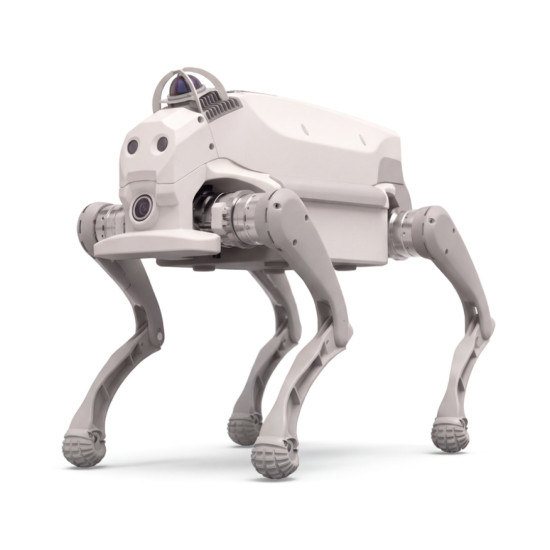
AgiBot D1 Ultra robotic system for security and territory monitoring
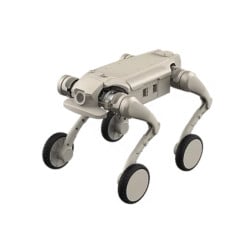
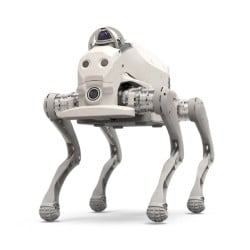
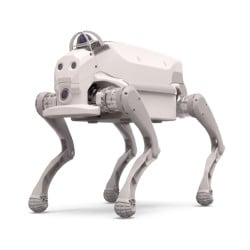
AgiBot D1 Ultra Patrol — is a robotic system for autonomous patrolling, video surveillance and technical inspection of facilities. The solution is based on the AgiBot D1 Ultra quadruped robot. Depending on the configuration, the system uses cameras, LiDAR and thermal imaging modules to monitor territories, detect obstacles and collect data. The software platform provides route management, remote monitoring and report generation.
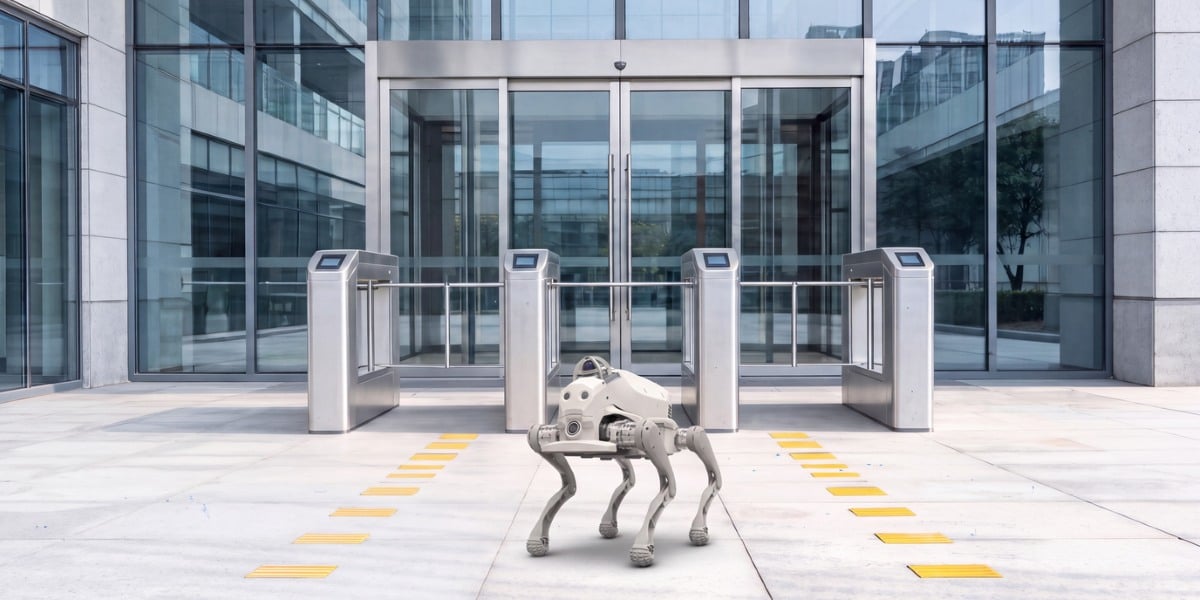
Key advantages of AgiBot D1 Ultra Patrol
- Adaptive motion control. Reinforcement Learning algorithms adjust limb movements to the terrain, maintain balance and help prevent tipping over.
- Obstacle negotiation. The robot climbs steps up to 16 cm high, traverses slopes with an incline of up to 40° and performs vertical jumps of up to 35 cm.
- Payload of up to 5 kg. The design allows additional cameras, sensors and equipment to be mounted for specialised tasks.
- Real-time video surveillance. A camera with a resolution of 1920 × 1080 pixels transmits the image to the operator for remote monitoring of the territory.
- Remote control. A controller with a screen lets the operator steer the robot and observe its surroundings.
- Autonomy of up to 2 hours. The 43.2 V battery provides 1–2 hours of operation depending on operating conditions.
- IP54 housing protection. The design is protected against dust and water splashes, and the main components have seals and anti-corrosion treatment.
- Navigation system expansion. The platform supports the connection of LiDAR, depth cameras and RTK modules for developing positioning and autonomous movement systems.
- SDK software development. Open interfaces make it possible to create custom control algorithms and connect additional equipment.
- Intelligent recognition. The software system supports face recognition, licence plate recognition and detection of parking violations.
- Automatic charging. Supported configurations return to the charging station on their own to recharge the battery.
- Centralised management. The software platform combines route setup, remote monitoring and task management.
- Automatic report generation. The system stores inspection results, event records and information about detected deviations.
Design and mobility of AgiBot D1 Ultra Patrol
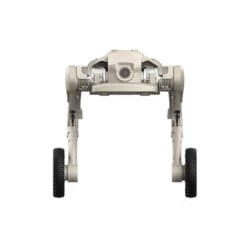
AgiBot D1 Ultra Patrol is built on a quadruped robotic platform with 12 degrees of freedom — three movable joints per limb. The design allows the body height to be changed, balance to be maintained and uneven surfaces to be traversed. The robot's dimensions in the working position are 630 × 360 × 420 mm, and its weight with the battery is 16 kg.
Electric drives with a peak torque of 48 N·m provide a speed of up to 3.7 m/s, the ability to climb steps up to 16 cm high and slopes with an incline of up to 40°. The robot is capable of performing vertical jumps of up to 35 cm. Reinforcement Learning (RL) algorithms adapt limb movements to the terrain and compensate for external mechanical disturbances.
The body is made of aluminium alloy and engineering plastic. The IP54 protection rating provides protection against dust and water splashes. The platform withstands a payload of up to 5 kg, which allows additional cameras, sensors and other equipment to be installed for security and inspection tasks.
Autonomous navigation and territory patrolling
The AgiBot D1 Ultra patrol configuration makes it possible to organise automated rounds of a territory along predefined routes. To implement autonomous navigation, the platform can be equipped with 3D LiDAR, depth cameras and RTK positioning modules. The navigation equipment is used to determine the robot's location, build a map of the territory and detect obstacles. Route planning algorithms allow the trajectory to be adjusted according to the surrounding conditions.
As part of the specialised patrol robot dog solution, the software system provides for setting up checkpoints, creating patrol tasks and carrying out inspections on a set schedule. The operator can monitor route progress, view the current state of the equipment and receive notifications about detected deviations. Autonomous navigation requires appropriate sensor equipment and software configuration, since the basic D1 Ultra platform has no built-in LiDAR navigation.
Video surveillance and thermal imaging monitoring
The AgiBot D1 Ultra is equipped with a camera with a resolution of 1920 × 1080 pixels and a horizontal field of view of 111°. Real-time video transmission allows the operator to inspect the territory remotely and monitor the robot's movement. To extend security surveillance functions, the patrol complex can be equipped with rotating PTZ cameras, thermal imaging modules and additional equipment. Infrared cameras are used to measure the temperature of industrial installations and electrical components and to detect local overheating.
The security patrol and inspection software system supports intelligent video analytics for face recognition, licence plate recognition and detection of parking violations. Image processing is carried out using cameras and computer vision algorithms. The availability of individual functions depends on the configuration of the AgiBot D1 Ultra patrol robot, the installed sensors and the software.
Patrol management software platform
AgiBot D1 Ultra Patrol supports secondary software development via the manufacturer's SDK. Standardised Ethernet, USB, SBUS and UART interfaces are intended for connecting external equipment and creating specialised control systems. To automate security and inspection tasks, the D1 Ultra Patrol solution provides a centralised software platform with the following functions:
- Checkpoint setup. Defining inspection locations and patrol route parameters.
- Task management. Creating schedules, setting up routes and monitoring patrol execution.
- Real-time monitoring. Viewing the status of the robotic platform and surveillance results.
- Data analysis. Processing information received from cameras and sensors during inspections.
- Results viewing. Access to the history of inspections and completed tasks.
- Deviation alerts. Logging events that require the operator's attention.
- Alert handling. Acknowledging received notifications and monitoring their processing.
The software system also provides for storing patrol results and generating inspection reports. The availability of the listed functions depends on the installed software package.
Automated inspection of industrial equipment
The AgiBot D1 Ultra patrol robot dog can be used to inspect industrial installations, electrical equipment and engineering infrastructure. The specialised patrol and inspection configuration includes the following functions:
- Thermal imaging monitoring. Measuring equipment temperature and detecting areas with temperature deviations.
- Acoustic inspection. Detecting unusual noises during the operation of industrial installations.
- Visual inspection. Assessing the external condition of equipment, structures and engineering units using cameras.
- Environmental parameter monitoring. Measuring temperature, humidity and other indicators with appropriate sensors.
- Automatic instrument reading. Recognising readings of pressure gauges, level indicators and other analogue measuring devices.
Inspection results are transmitted to the software platform for analysis, storage and generation of notifications about detected deviations. The availability of individual functions depends on the installed equipment and software.
Application areas of AgiBot D1 Ultra Patrol
The AgiBot D1 Ultra patrol robot dog is designed for remote surveillance, security patrolling and automation of regular facility inspections.
- Industrial enterprises. Rounds of production sites, technological passageways and restricted-access areas.
- Energy infrastructure. Inspection of electrical substations, transformers and switchgear.
- Logistics complexes. Security rounds of warehouse premises, loading areas and adjacent territories.
- Commercial facilities. Access control and patrolling of business centres, industrial parks and private territories.
- Transport infrastructure. Surveillance of station areas, terminals and transport hubs.
- Mass events. Remote surveillance of public areas and recording of events.
- Municipal infrastructure. Surveying engineering structures, technical premises and hard-to-reach areas.
AgiBot D1 Ultra Patrol technical specifications
Design and operating characteristics
| Parameter | Value |
| Body material | Aluminium alloy, high-strength engineering plastic |
| Degrees of freedom | 12 |
| Motion control algorithm | Reinforcement Learning |
| Maximum speed | 3.7 m/s |
| Payload | 5 kg |
| Travel range | 6 ± 1 km |
| Step height | Up to 16 cm |
| Slope climbing angle | 40° |
| Maximum jump height | 35 cm |
| Peak joint torque | 48 N·m |
| Body range of motion | −28°…+28° |
| Hip joint range of motion | −170°…−66° |
| Shank joint range of motion | +35°…+156° |
| Drive control system | Dual encoders |
| Protection rating | IP54 |
| Operating temperature | 0…+40 °C |
| Net dimensions, folded position | 670 × 435 × 145 mm |
| Net dimensions, working position | 630 × 360 × 420 mm |
| Net weight | 16 kg |
Control and power supply
| Parameter | Value |
| Inertial sensor | IMU |
| Camera resolution | 1920 × 1080 pixels |
| Camera fields of view | 122° / 111° / 70° |
| Real-time video transmission | Supported |
| Target tracking | Supported |
| Battery capacity | 5 / 4.6 Ah |
| Battery voltage | 43.2 V |
| Battery life | 1–2 hours |
| Charging time | Approximately 1 hour (10–90%) |
| Wi-Fi | Wi-Fi 5, 2.4 GHz |
| Wi-Fi transmit power | 21 dBm |
| Bluetooth | 5.0 |
| Ethernet | 1 port |
| USB | 2 ports |
| Power ports | 2 |
| SBUS | 1 port |
| UART | 1 port |
| Software development | SDK |
| URDF support | Yes |
| Simulation environments | NVIDIA Isaac Sim, MuJoCo |
Buy AgiBot D1 Ultra Patrol robotic systems for autonomous territory patrolling, remote video surveillance and technical inspection of industrial facilities. Our specialists will help you choose the right version, define the sensor equipment configuration and advise on the possibilities of using the robots at your enterprise.